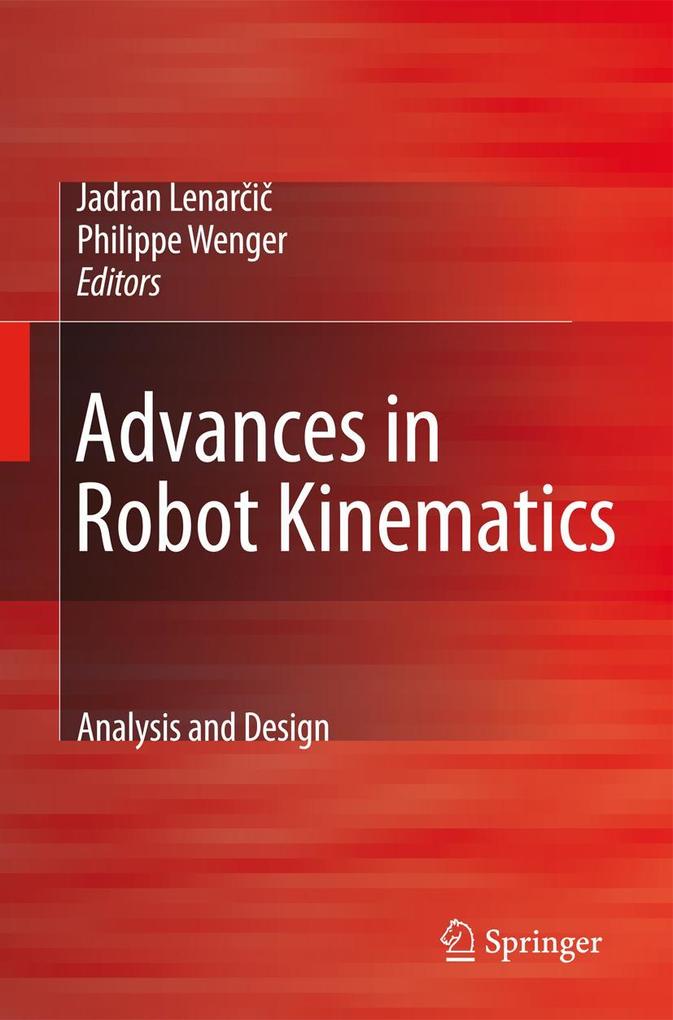
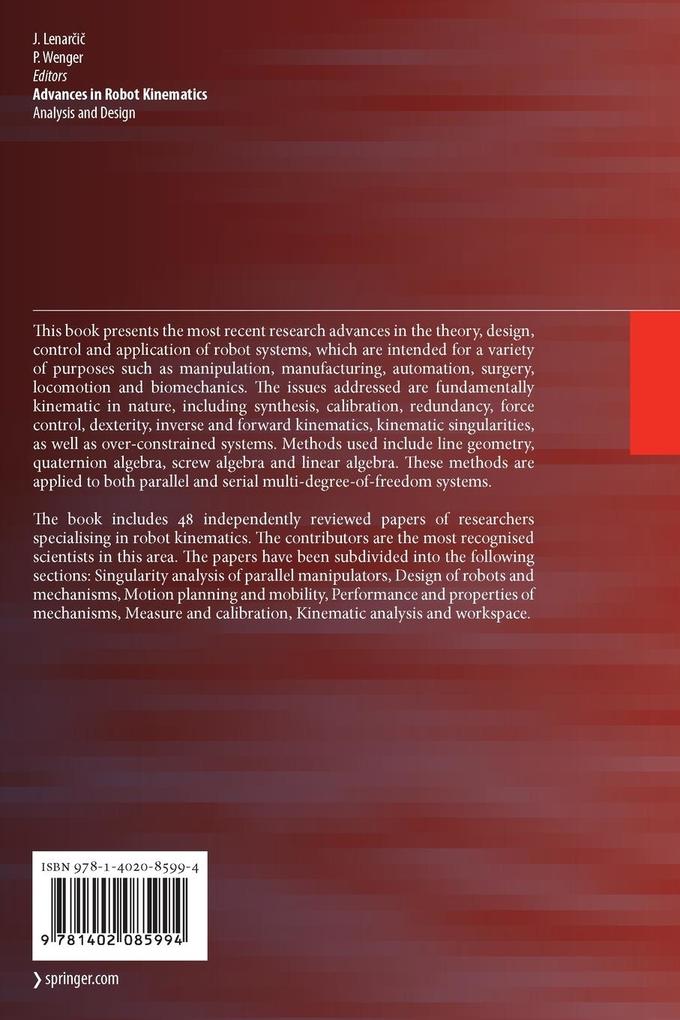
Singularity Analysis of Parallel Manipulators.- A New Assessment of Singularities of Parallel Kinematic Chains.- Singularity Analysis through Static Analysis.- Constraint Singularities and the Structural Parameters of Parallel Robots.- Forward Kinematics and Singularity Analysis of a 3-RPR Planar Parallel Manipulator.- Geometric Algebra Approach to Singularity of Parallel Manipulators with Limited Mobility.- SinguLab - A Graphical User Interface for the Singularity Analysis of Parallel Robots Based on Grassmann-Cayley Algebra.- Singularity Analysis of Limited-DOF Parallel Manipulators Using Grassmann-Cayley Algebra.- Design of Robots and Mechanisms.- On the Design of Fully Constrained Parallel Cable-Driven Robots.- Synthesis of Part Orienting Devices for Spatial Assembly Tasks.- Minimum Energy Manipulator Design.- Synthesis and Analysis of a Constrained Spherical Parallel Manipulator.- A Nonholonomic 3-DOF Parallel Robot.- 4-DOF Parallel Architecture for Laparoscopic Surgery.- Flapping-Wing Mechanism for a Bird-Sized UAVs: Design, Modeling and Control.- Methods in Kinematics.- Extended Jacobian Inverse Kinematics and Approximation of Distributions.- A Screw Syzygy with Applications to Robot Singularity Computation.- Singularity Robust Jacobian Inverse Kinematics for Mobile Manipulators.- Robots Based on Assur Group A (3.5).- Kinematics of Free-Floating Systems through Optimal Control Theory.- Genericity Conditions for Serial Manipulators.- Alternative Forms for Displacement Screws and Their Pitches.- Motion Planning and Mobility.- Time-Invariant Strategies in Coordination of Human Reaching.- Mobility and Higher Order Local Analysis of the Configuration Space of Single-Loop Mechanisms.- Optimization of a Test Trajectory for SCARA Systems.- Singularity Free PathPlanning for Parallel Robots.- A Comparison between Two Motion Planning Strategies for Kinematically Redundant Parallel Manipulators.- Trajectory Planning of Parallel Manipulators for Global Performance Optimization.- Human Motion Reconstruction by Direct Control of Marker Trajectories.- Performance and Properties of Mechanisms.- New Self-Motions of Parallel Manipulators.- Exact Envelope Computation for Moving Surfaces with Quadratic Support Functions.- A Compound-Structure Frame for Improving the Performance of a Dielectric Elastomer Actuator.- Transitions between Multiple Solutions of the Direct Kinematic Problem.- Kinetostatic Performance of a Planar Parallel Mechanism with Variable Actuation.- Results on Planar Parallel Manipulators with Cylindrical Singularity Surface.- Stiffness Matrix of Compliant Parallel Mechanisms.- Measure and Calibration.- A Pair of Measures of Rotational Error for Axisymmetric Robot End-Effectors.- Angular-Velocity Estimation from the Centripetal Component of the Rigid-Body Acceleration Field.- A Novel Point of View to Define the Distance between Two Rigid-Body Poses.- Parallel Robot Calibration by Working Mode Change.- Augmented Model of the 3-PRS Manipulator for Kinematic Calibration.- The Calibration of a Parallel Manipulator with Binary Actuation.- Stability Measure of Postural Dynamic Equilibrium Based on Residual Radius.- Kinematic Analysis and Workspace.- A Geometrical Characterization of Workspace Singularities in 3R Manipulators.- Kinematic Analysis of a Planar Tensegrity Mechanism with Pre-Stressed Springs.- Inverse Kinematics of Robot Manipulators with Multiple Moving Control Points.- On the Delassus Parallelogram.- Forward Kinematics and Workspace Determination of a Wire Robot for Industrial Applications.- Kinematic Modeling and Workspace Generation for a New Parallel Robot Used in Minimally Invasive Surgery.
Inhaltsverzeichnis
Singularity Analysis of Parallel Manipulators. - A New Assessment of Singularities of Parallel Kinematic Chains. - Singularity Analysis through Static Analysis. - Constraint Singularities and the Structural Parameters of Parallel Robots. - Forward Kinematics and Singularity Analysis of a 3-RPR Planar Parallel Manipulator. - Geometric Algebra Approach to Singularity of Parallel Manipulators with Limited Mobility. - SinguLab A Graphical User Interface for the Singularity Analysis of Parallel Robots Based on Grassmann Cayley Algebra. - Singularity Analysis of Limited-DOF Parallel Manipulators Using Grassmann Cayley Algebra. - Design of Robots and Mechanisms. - On the Design of Fully Constrained Parallel Cable-Driven Robots. - Synthesis of Part Orienting Devices for Spatial Assembly Tasks. - Minimum Energy Manipulator Design. - Synthesis and Analysis of a Constrained Spherical Parallel Manipulator. - A Nonholonomic 3-DOF Parallel Robot. - 4-DOF Parallel Architecture for Laparoscopic Surgery. - Flapping-Wing Mechanism for a Bird-Sized UAVs: Design, Modeling and Control. - Methods in Kinematics. - Extended Jacobian Inverse Kinematics and Approximation of Distributions. - A Screw Syzygy with Applications to Robot Singularity Computation. - Singularity Robust Jacobian Inverse Kinematics for Mobile Manipulators. - Robots Based on Assur Group A (3. 5). - Kinematics of Free-Floating Systems through Optimal Control Theory. - Genericity Conditions for Serial Manipulators. - Alternative Forms for Displacement Screws and Their Pitches. - Motion Planning and Mobility. - Time-Invariant Strategies in Coordination of Human Reaching. - Mobility and Higher Order Local Analysis of the Configuration Space of Single-Loop Mechanisms. - Optimization of a Test Trajectory for SCARA Systems. - Singularity Free PathPlanning for Parallel Robots. - A Comparison between Two Motion Planning Strategies for Kinematically Redundant Parallel Manipulators. - Trajectory Planning of Parallel Manipulators for Global Performance Optimization. - Human Motion Reconstruction by Direct Control of Marker Trajectories. - Performance and Properties of Mechanisms. - New Self-Motions of Parallel Manipulators. - Exact Envelope Computation for Moving Surfaces with Quadratic Support Functions. - A Compound-Structure Frame for Improving the Performance of a Dielectric Elastomer Actuator. - Transitions between Multiple Solutions of the Direct Kinematic Problem. - Kinetostatic Performance of a Planar Parallel Mechanism with Variable Actuation. - Results on Planar Parallel Manipulators with Cylindrical Singularity Surface. - Stiffness Matrix of Compliant Parallel Mechanisms. - Measure and Calibration. - A Pair of Measures of Rotational Error for Axisymmetric Robot End-Effectors. - Angular-Velocity Estimation from the Centripetal Component of the Rigid-Body Acceleration Field. - A Novel Point of View to Define the Distance between Two Rigid-Body Poses. - Parallel Robot Calibration by Working Mode Change. - Augmented Model of the 3-PRS Manipulator for Kinematic Calibration. - The Calibration of a Parallel Manipulator with Binary Actuation. - Stability Measure of Postural Dynamic Equilibrium Based on Residual Radius. - Kinematic Analysis and Workspace. - A Geometrical Characterization of Workspace Singularities in 3R Manipulators. - Kinematic Analysis of a Planar Tensegrity Mechanism with Pre-Stressed Springs. - Inverse Kinematics of Robot Manipulators with Multiple Moving Control Points. - On the Delassus Parallelogram. - Forward Kinematics and Workspace Determination of a Wire Robot for Industrial Applications. - Kinematic Modeling and Workspace Generation for a New Parallel Robot Used in Minimally Invasive Surgery.